NVIDIA Isaac ROS 5.0 brings agents into robotics development
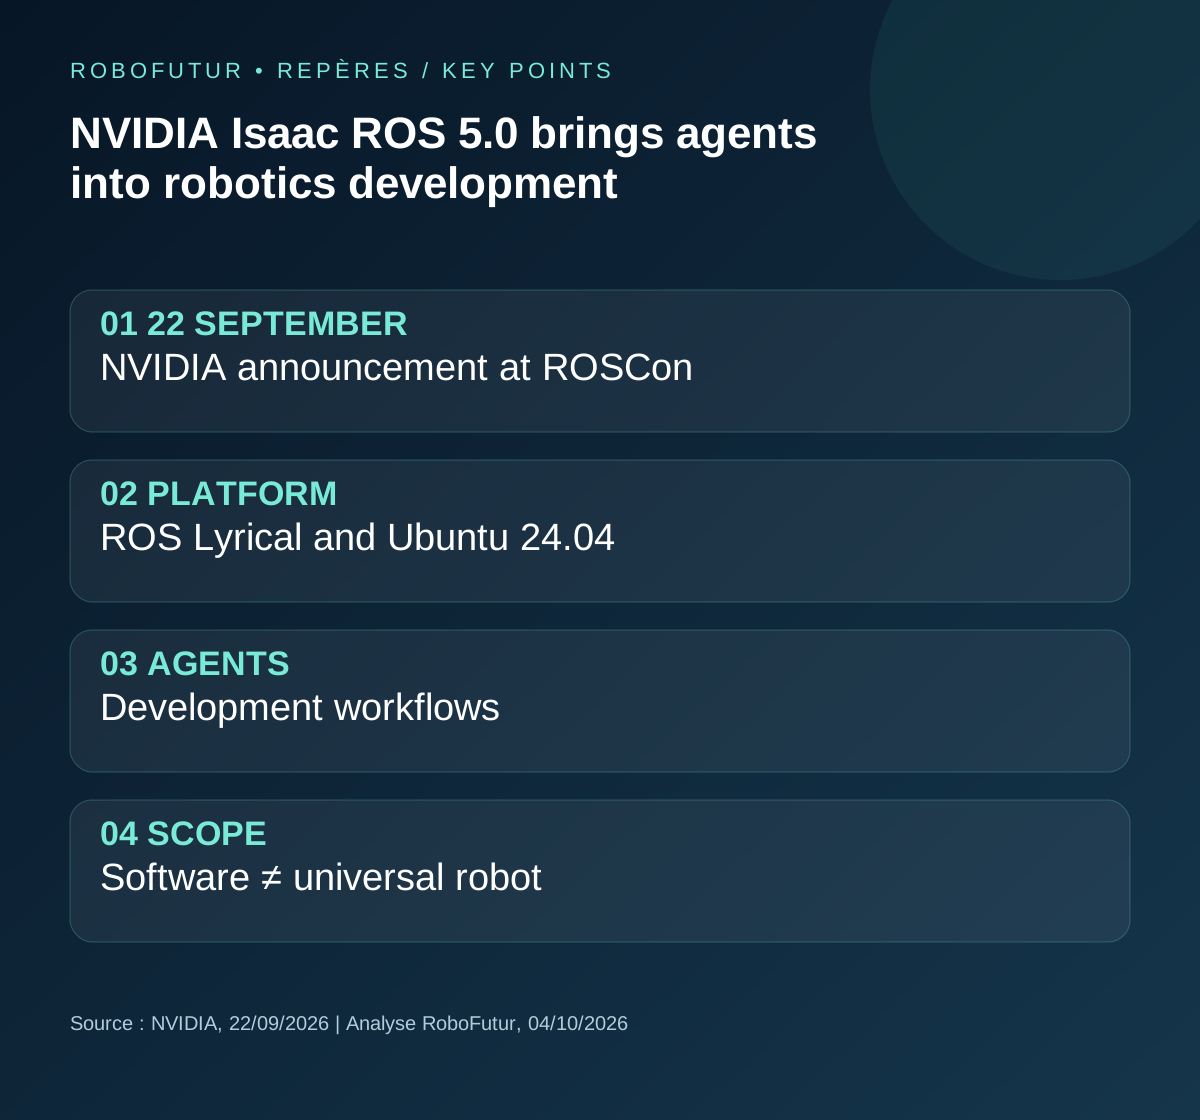
On 22 September 2026, NVIDIA announced Isaac ROS 5.0 at ROSCon. The company describes ROS Lyrical and Ubuntu 24.04 support, agent-oriented workflows, and perception and manipulation tools. This is a robotics development-stack release, not a new consumer robot.
A software layer connecting robot functions
Perception, computing and control need coherent data exchanges to produce useful motion. A stack update can matter across robot forms without changing their mechanics. It illustrates part of the work between an AI model and a physical action.
Development agents and operational autonomy
Helping configure an environment or prepare software does not establish that a robot performs every task independently. Development assistance and deployed robot control require separate evidence.
Evaluate perception in context
A team should evaluate its sensors, objects and available computing. Comparisons need resolution, environment, hardware and task details. We report no universal ranking or independently measured performance gain.
Reproducibility is practical
A rebuildable environment helps distinguish code problems from changed dependencies. Versions and representative trials matter before migration. Open software and total deployment cost remain different questions.
Evidence to follow
The release affects a robotics ecosystem beyond one hardware manufacturer. Reproducible projects, documented limits and use-context trials will be useful follow-up evidence. Feature counts do not substitute for task success.
✔ How we checked this
NVIDIA primary announcement dated 22 September; checked on 4 October 2026. Attributed claims, no independent RoboFutur test.
Information verified as of the publication or update date shown. Technology moves fast — check the sources below.